Drone Swarm
trajectory tracking and formation control
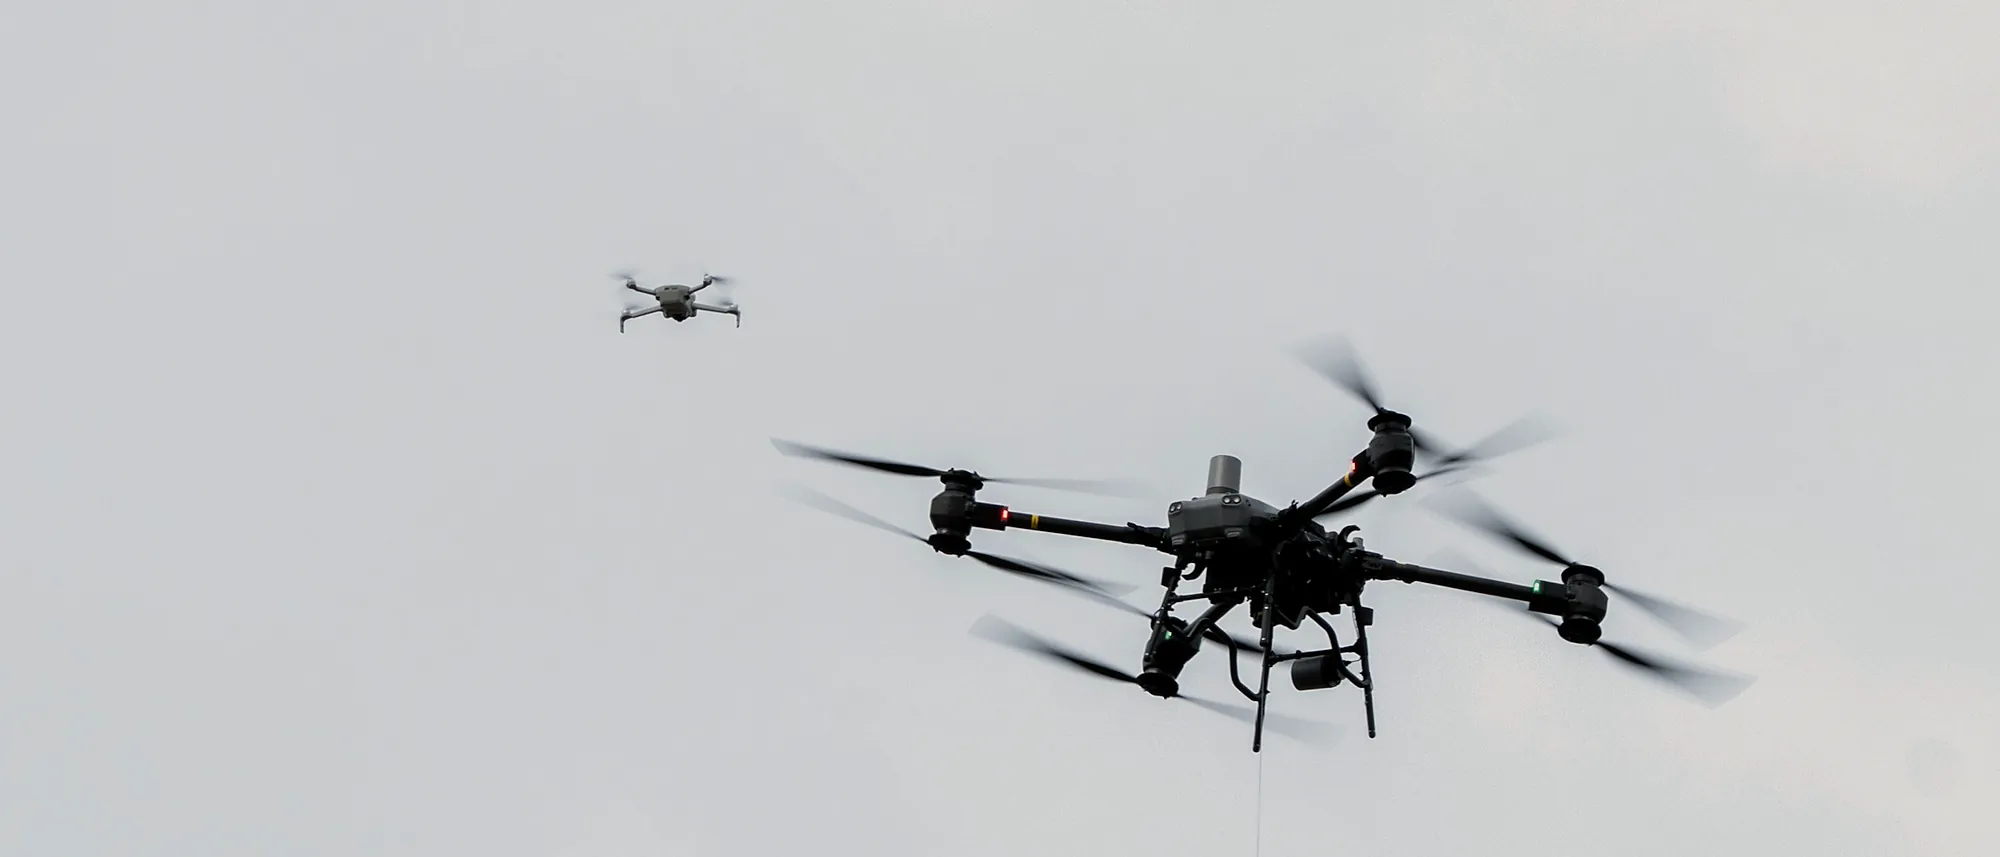
Dozens of drones holding formation looks like magic; it is a control law. Three nano-drones, a guidance vector field that provably converges onto a circular trajectory under a Lyapunov condition, and a formation controller that holds the shape when one drone drifts. Proven in Gazebo, then flown for real under motion capture, with ArUco perception, Kalman filtering and optical flow closing the gap between simulation and hardware.