Not Rocket Science
visual servoing guidance simulator
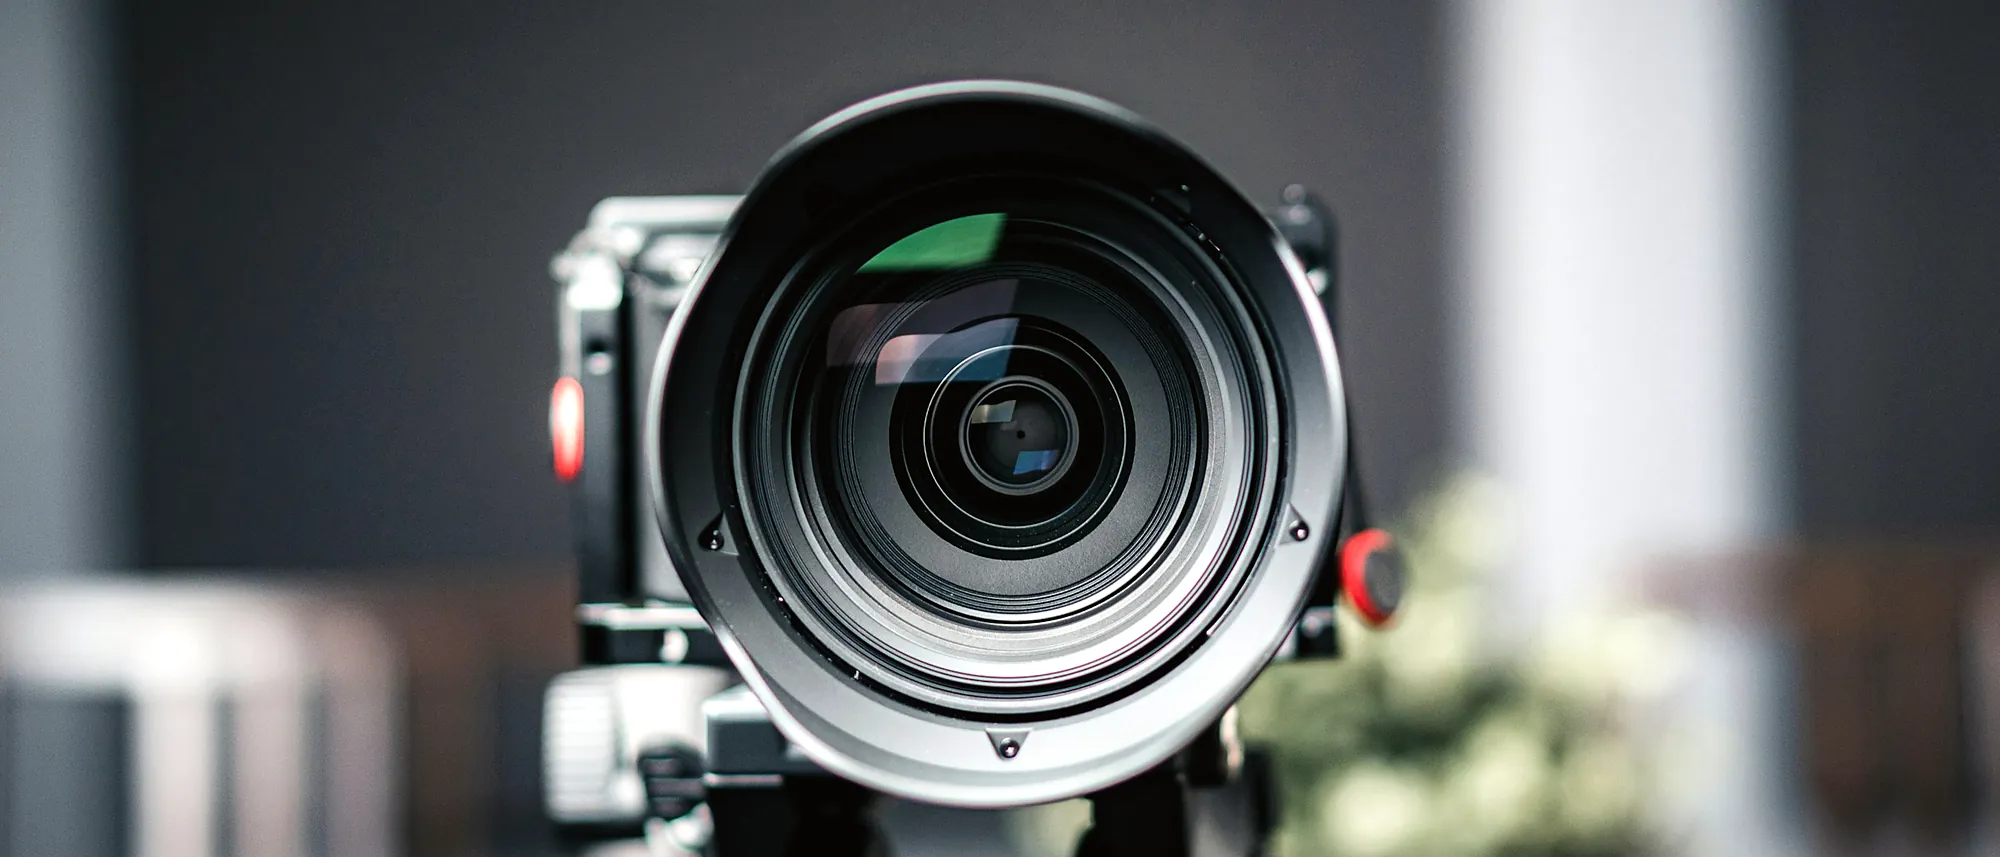
A camera on a pan-tilt gimbal locks onto a target and refuses to let go. Every frame becomes a line-of-sight measurement, streamed over UDP into a Simulink interceptor flying Pure Pursuit, LOS guidance and Proportional Navigation. Real optics at one end, a simulated vehicle at the other: a seeker-in-the-loop rig built from a Raspberry Pi, two servos and guidance theory worked out from the ground up.